Showing posts with label drongle mcmahon. Show all posts

Saturday, 1 October 2016

Bug hunting - Fixing an ancient LOD issue

Those of you who may have read my blog post in July, "Tell your friends - An old bug that people really ought to know about." might be interested to know that I have made a lot of progress towards fixing it.

TL;DR

The long-standing bug discussed in the blog (see link above) that impacts the way that certain Mesh objects decay their LODs has been identified and fixed. I will be submitting the patch to Firestorm and other TPVs where applicable and back to the Lab so that (if it is accepted) we can be rid of this pain in the posterior.

Introduction

After having suffered and grumbled at this bug for a long time I decided to bite the bullet and for the first time since about 2009, build and debug the viewer. After a week or so of digging around and working out how V3 viewers hang together, I now have a solution to the problem we observe, but it still needs to go through QA and of course the thing I cannot know...why did it do that? More of that later...

The basic problem

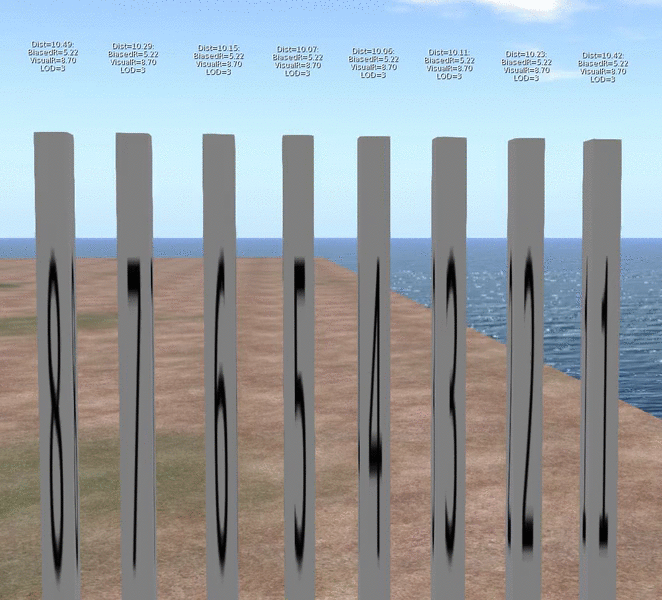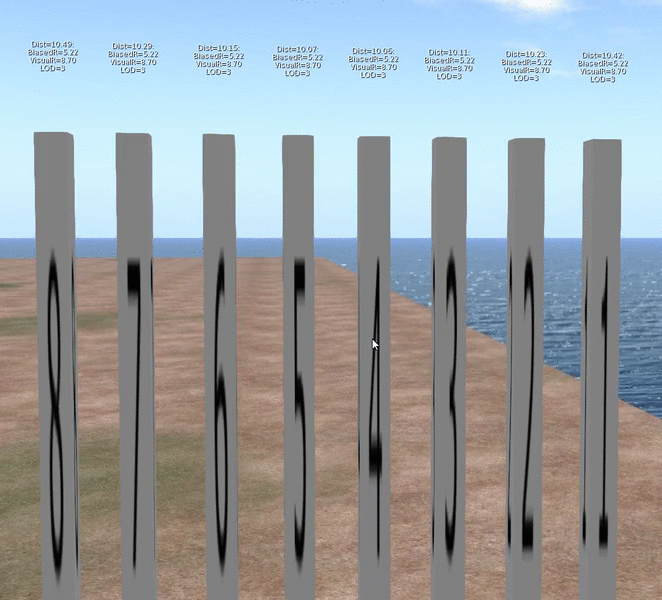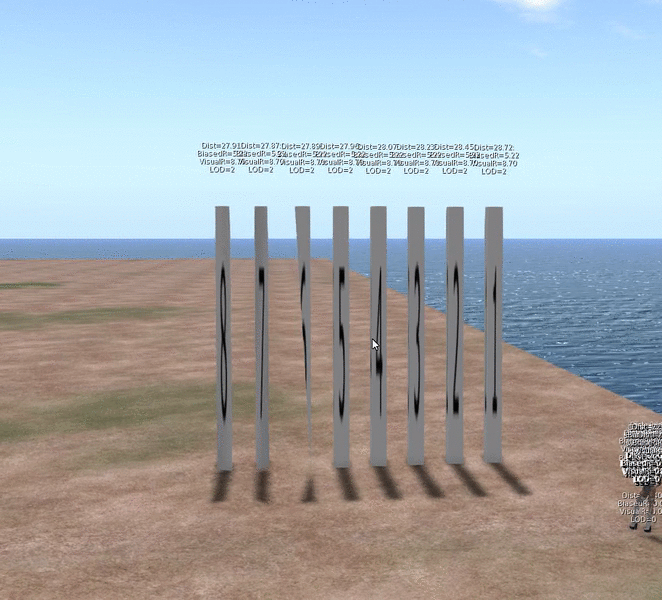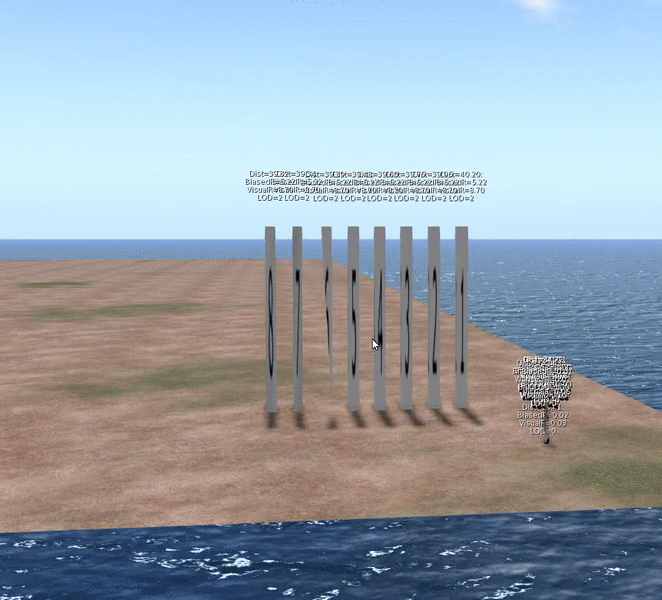
Here is the basic problem as we originally observed it.

Any mesh object with either 3 or 4 texture faces will crumple earlier than an identically sized mesh with only 2 texture faces.

But in fact it is worse than that (a little).

As I dug into this problem it turns out that this is not a problem that affects 3 and 4 materials only, it just affects them worse. Meshes with 5, 6, 7 & 8 material faces will also collapse earlier than the comparable 1 and 2 material versions. The following image will illustrate
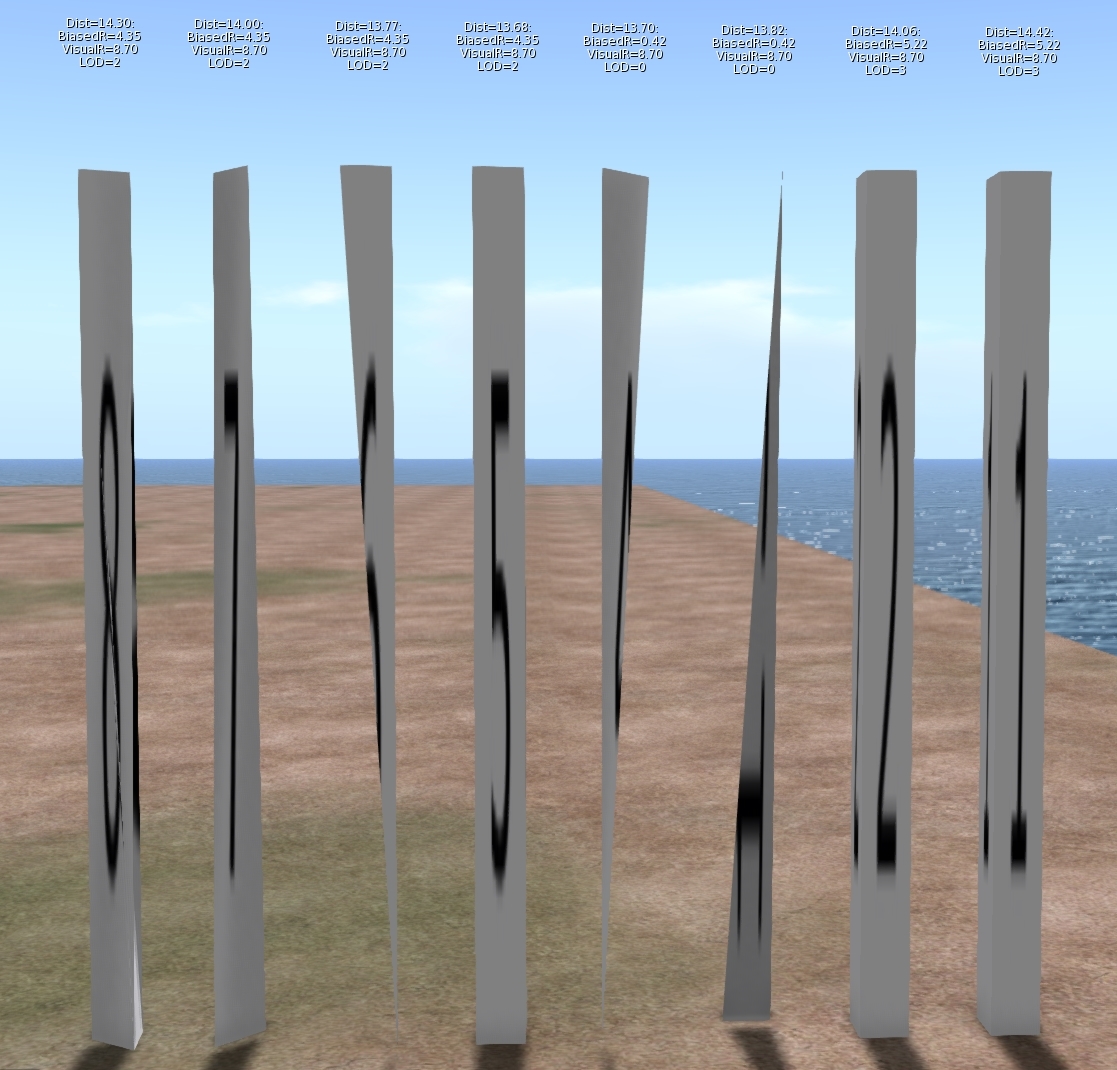
The image shows 8 identically sized columns. Under normal circumstances, one would expect these to look identical and change LOD at the same distance from the viewer. The textual display above each shows the following:
Dist:                   The distance of the object from the viewer.
Biased Radius:   An adjusted radius based upon a biasing algorithm, the source of our woes.
Visual Radius:    The "True" Radius defined by the bounding box of the object.
LOD:                  The Level Of Detail currently shown. 3=HIGH, 2=MED, 1=LOW, 0=LOWEST

The display is a bug fix/enhancement of my own and if accepted will appear in a future viewer. It is a change to the existing Render Metadata -> LOD Info which is basically broken on all existing viewers. I should also note that I use the term radius here, because not only is it the term we use inworld when examining the LOD equations, but it is also used in the code, all of which is despite the fact that it is not the radius at all but the long diagonal of the bounding box!

As you can see, Objects 1 & 2 are still at LOD 3, even though their distance from the camera is marginally more than the others. Further scrutiny of the hovering figures shows that the Biased Radius is 5.22 compared to 4.35and 0.42. Objects 3 & 4 have collapsed to LOD 0, with a biased Radius of just 0.42 they had little hope of remaining visible. While all the others have decayed to a slightly withered LOD2.

But why does this happen? To understand this we need a little implementation detail.

What does a mesh look like on the inside?

SL is often criticised and even rubbished for the way it does things, but if I am really honest I have a great deal of admiration for the general architecture. For a system design 15 years ago it has managed to grow and adapt and shown remarkable durability. The code certainly bears many battle scars and the stretch marks of its adolescence glare an angry red under scrutiny but the fact that it has gone from super optimised prims through to industry standard Mesh, growing as and when the technology of its users was best able to adopt it is very impressive. 

Second Life has achieved this longevity through a series of "cunning plans" which have extended the capability without altering the infrastructure drastically. all the objects in your inventory have a top level structure which is basically a legacy prim, extensions have been variously grafted on to this but leave behind the traits of the original prims. This means that, even though they are unused, a mesh has a slice, taper and cut setting as well as many others.

These top level prims also denote what type of prim they are, cube, sphere, cone, etc. and Meshes are no different. The basic shape is determined through two parameters the PATH and the PROFILE. Thus a sphere has a PATH and PROFILE of CIRCLE, while a cylinder has a PATH of LINE and a PROFILE of CIRCLE. Sculpts came along later and are indicated by the presence of a sculpt parameter block on the end of the Prim. Perhaps surprisingly Mesh is denoted as a type of Sculpt with the "SculptType" is set to the value 5 representing Mesh.

This allows the "cunning plan" that the settings for a sculpt can be reused. In a traditional sculpted prim, the SculptID holds the asset server UUID of an image that defines the sculptmap. In a Mesh the same field is used to hold a UUID of the underlying Mesh. It is important to note here that the Mesh that you upload is given this UUID that is the "child" of the Mesh object. You never actually get to see or know the underlying Mesh asset ID inworld.

So we now know that a Mesh is really a legacy prim, denoted as a sculpt, whose map is redirected to a Mesh defintion. So let's see where it goes wrong.

LODScaleBias and the legacy impact.

My first task in trying to fix this bug was to start to map out the viewer. It has been at least 6 years since I last looked at the viewer code and back then I was only really building it for my own purposes. The code has all the hallmarks of mature and much patched and extended code and is a bit of a rat's nest at times, but nestled deep inside the nest is a function simply called calcLod()
This function, along with the name, also was home to the output for the Render Metadata->LOD Info function.
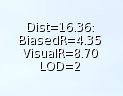
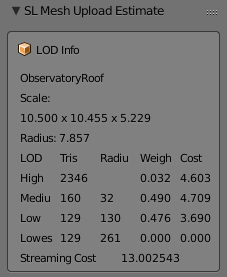
The Render Metadata services are a set of great tools for builders and developers who are trying to understand a problem, those who have read this blog in the past will be well aware of the physics display. The LOD Info display has been a bugbear of mine for some time, I have never been able to work out what it was displaying, It would show a number that would typically not change with the LOD display and was to all intents and purposes useless. It turns out that is exactly what it is. At some point in the past it appears to have been borrowed for some other purpose and upon examination had nothing to do with the LOD at all. The damning evidence was a commented out remnant of the original call. My first "fix" of the expedition was, therefore, to make this function more useful, the new display is shown on the left. I will be submitting that patch separately.

Back to our friend calcLOD().
I won't post the code here, it is too long but the function does what you would expect it to do given its name but the devil is in the detail.

BOOL LLVOVolume::calcLOD()
{
F32 radius;
F32 distance;

if (mDrawable->isState(LLDrawable::RIGGED))
{
// if this is rigged set the radius to that of the avatar              
}
else
{
distance = mDrawable->mDistanceWRTCamera;
radius = getVolume() ? getVolume()->mLODScaleBias.scaledVec(getScale()).length() : getScale().length();
}
.....etc etc
}

There are a couple of interesting diversions in this function, the first we covered above, the second is a special clause for rigged attachments which deliberately adjusts their LOD scale to be that of the avatar that is wearing them. This is the subject of a Jira and is likely to come under scrutiny in the current quest to improve complexity determination.
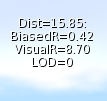
However it is the code in bold and further highlighted that we care about. What is this LODScaleBias? Our amended LODInfo display proves that this is the culprit. The BiasedRadius of a 3 face Mesh is shown on the left and can be compared to the same mesh with 6 material faces shown in the example above. 0.42 when the true radius is 8.7, no wonder the thing crumbles. 

Digging deeper we can identify where the LODScaleBias vector is initialised. 
BOOL LLVolume::generate(){
...snip...
    mLODScaleBias.setVec(0.5f, 0.5f, 0.5f);
...snip...        
    if (path_type == LL_PCODE_PATH_LINE && profile_type == LL_PCODE_PROFILE_CIRCLE)
    { //cylinders don't care about Z-Axis
        mLODScaleBias.setVec(0.6f, 0.6f, 0.0f);
    }
    else if (path_type == LL_PCODE_PATH_CIRCLE) 
    {    
        mLODScaleBias.setVec(0.6f, 0.6f, 0.6f);
    }

 ...
So here we have it.

"Cylinders don't care about Z-Axis"

The code above sets up the bias. The default bias is <0.5, 0.5, 0.5> and I'm feeling rather stupid now because having said previously that Radius is not really the radius...if you take the long diagonal and half it then of course you do have the radius (the radius of a sphere that encloses the bounding box, at least.) We then get to the code in bold red. Here we find that if the legacy prim has a linear path and a circular profile then it must be a cylinder, 
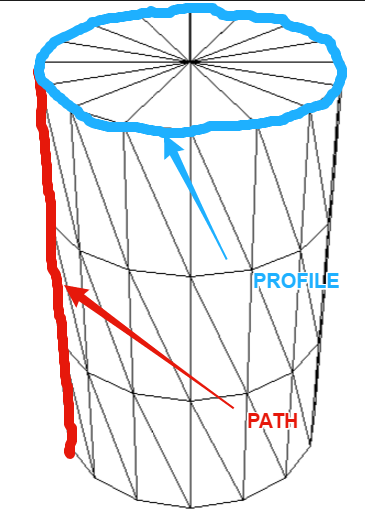
The image to the left shows my hand drawn annotation of what those two parameters mean. Anyone who worked with prims will most likely understand the terms.

This does pose a couple of questions, the most obvious of which is:-
"Cylinders don't care about Z-Axis" WHY!!!!?

There seems no logic to explain why a cylinder would be set to LOD quicker. Clearly, when used as a column it results in a high number of long thin triangles but does that really warrant such punishment? I have enquired with a couple of Lindens to see if we can get some clarification on the history of this.

Noting the <0.6, 0.6, 0.0> when applied to our example mesh columns give a Radius of 0.42 we can confirm that this is , as had been suspected, how out poor Meshes are being evaluated, and so the second most obvious question is:-
Why is my Mesh arbitrarily being branded as a cylinder? 
Again there seems no rhyme nor reason to the 3 and 4 material face meshes being treated this way. If the lab responds with an answer to either of these I will post a blog to share the info.

Having determined why we have this issue we need to go and find out where. At first, this seemed a daunting task. Somewhere in all the viewer code was a single line or two that was initialising these parameters incorrectly. I decided to start at the very beginning. The beginning for any asset is when it gets sent from the server to the client, a little hunting and we find a function that is called to process and unpack an update message for an object. In this code, I found the point at which the parameters are unpacked and placed some additional logging to print out the settings. 

Lo and behold the viewer is not to blame at all. The Object is already tainted before it arrives. This means that something is happening on the server and it would seem to be deliberate. 

How can we assume it is on the server? 

We have in previous blogs examined the Mesh Asset upload format and can note that there is no room in there for the legacy parameters. Moreover, that asset is the data that is referenced as the "SculptId". The Containing/parent prim is different, it is created on the server side, presumably during the validation of the upload process, the initilisation of the parent object must be assigning default values based on certain consistent criteria and as such results in the problem. As with the above, I have asked the lab whether they can confirm the reason for this, primarily so that we can understand if there are any side effects.

Having noted that Meshes are already tainted I added code to list out the types of Mesh and using a conveniently empty sim on the beta grid Aditi I created my series of 8 "identical" meshes.
the result can be summarised as follows.

# faces
PATH
PROFILE
BIAS
1
CIRCLE
CIRCLE_HALF
<0.6,0.6,0.6>
2
CIRCLE
CIRCLE
<0.6,0.6,0.6>
3
LINE
CIRCLE
<0.6,0.6,0.0>
4
LINE
CIRCLE
<0.6,0.6,0.0>
5
LINE
EQUALTRI
<0.5,0.5,0.5>
6
LINE
SQUARE
<0.5,0.5,0.5>
7
LINE
SQUARE
<0.5,0.5,0.5>
8
LINE
SQUARE
<0.5,0.5,0.5>

That is the end really. With the fix in place the Meshes quickly resolve and the new LOD Info display confirms that the Bias is no longer unfairly having some meshes. As for side-effects, we only modify at run time, and nothing is ever saved back to the server. Moreover I have implemented this to be configurable and should any issues arise it could be easily disabled. 

So what next? 

I am no cleaning up the code to remove or at lesat comment out any of the debug logging I used. I will then create a submit a patch to Firestorm. Having spoken to Oz Linden, I have been asked to sign a contribution agreement, this is a form that protects the Lab (and thus all of us) from me giving code and then claiming some licensing later.Once I have that in place the lab can accept my change and would then consider it. So that means that subject to QA and testing to follow hopefully we can put this bug to rest once and for all. 

It leaves a few loose ends. 

Why does a Cylinder ignore the Z? I just want to know.
Why does the server do this and will/should the server-side get fixed?
Would fixing this on the server make a difference to the SL Map

That's all for now, I shall leave you with an animation of the FIX in action,
Love

Beq
x

Saturday, 30 July 2016

Blender mesh data deep dive.

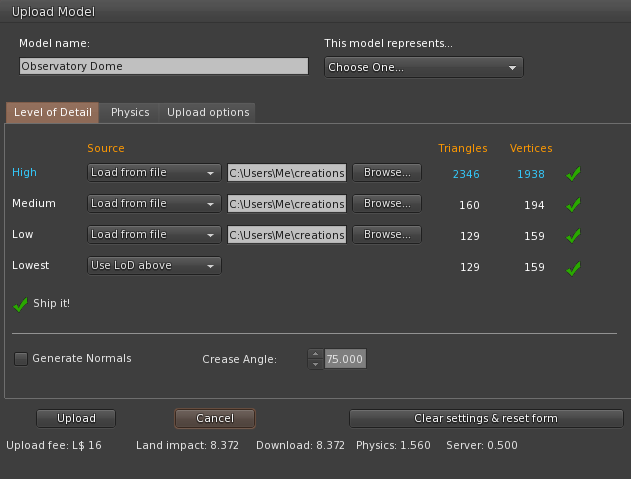
It's been a while since we last had a post on my quest to write better workflow tools for Second Life Mesh creators using Blender. In the last of that series, we took a long hard look at what exactly was meant by download cost and why our naive triangle counter was giving us such overestimates. Now it is time to try to use some of that knowledge to see how we can build that from Blender.

Decompression sickness

It was the compressed byte stream that was throwing out our numbers and, as a result, we will need to reproduce the data and compress it to find the byte streaming cost. This means that we need to look at how the polygons are stored in Blender.

We did a little of this when we were counting the triangles but we barely scratched the surface. 
All the data we need is in the bpy.data structure for a mesh object.

The BPY data structure is not very well documented but there is a lot of code around and the excellent blender python console that lets you try things out and features autocomplete.

Given an arbitrary mesh object (obj) we can access the mesh data itself through obj.data

import bpy

obj = bpy.context.scene.objects.active # active object

mesh = obj.data
Within obj.data we have access to a list of vertices and a list of polygons and a vast array of other attribute and views on the data.

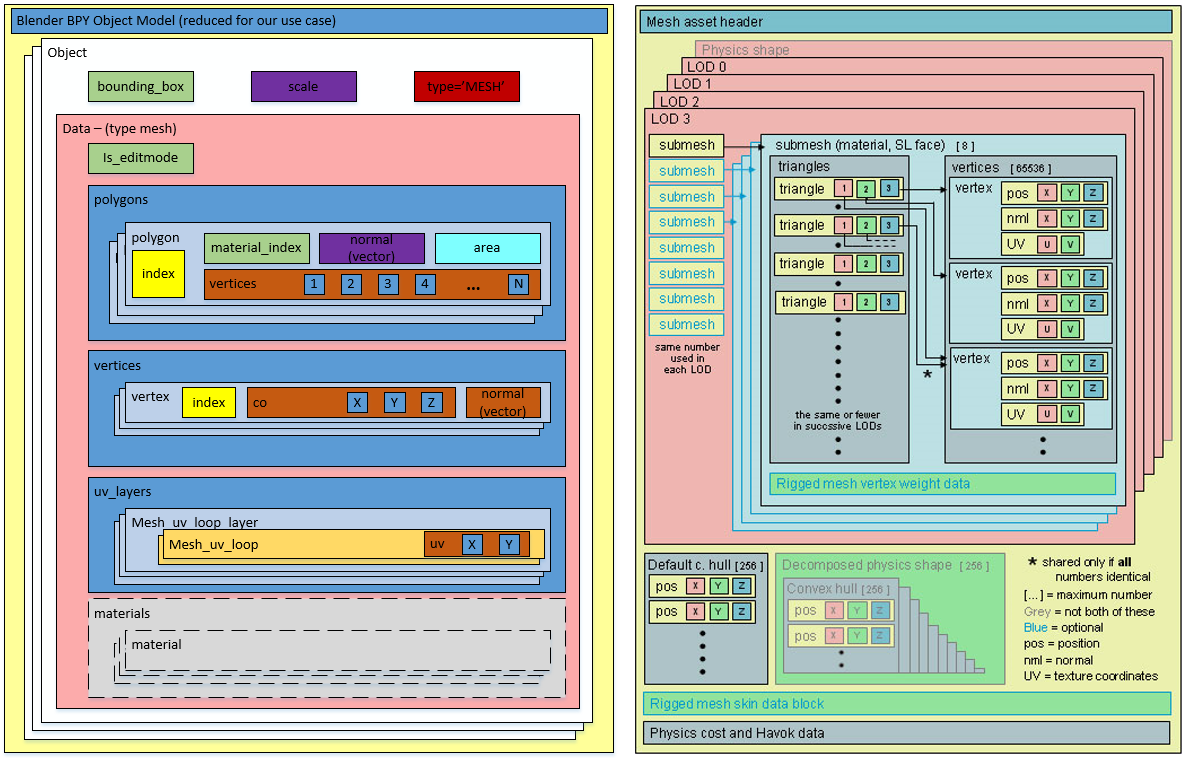
Following in the footsteps of the wonderful visualisation of the SL Mesh Asset Format by Drongle McMahon that we discussed in a previous blog I have had a stab at a comparable illustration that outlines the parts of the blender bpy data structure that we will need access for our purposes
On the left, we have my "good parts version" of the BPT datastructure, while on the right we have the SL Mesh Asset visualisation from Drongle McMahon's work.

We can now start to list out the differences and thus the transformations that we will need to apply
  1. SL Mesh holds all the LODs in one "object". We have multiple objects, one per LOD.
  2. A Mesh object has a list of polys that index into a list of vertices. SL has multiple meshes, split as one per material face
  3. SL only accepts triangle, we have Quads and NGons as well.
  4. Each submesh is self contained, with triangles, UVs, normals and vertices listed. Vertices are thus duplicated where they are common to multiple materials.
  5. SL data is compressed
So let's sketch out the minimum code we are going to need here.

For each Model in a LOD model set.
    Iterate through the polygons, and separating by material
    For each resulting material mesh
        for each poly in the mat mesh
             add new verts to the vert array for that mat. mesh
             adjust the poly into triangles where necessary
             add the resulting tris to the material tri array
             write the normal vector for the triangles
             write the corresponding UV data.
    compress the block

Having done the above we should be able to give a more accurate estimate.

A lot easier said than done...Time to get coding...I may be some time.

Love

Beq
x


Saturday, 16 July 2016

When is a triangle not a triangle? (mesh streaming)

When is a triangle not a triangle?
(when it's compressed)

Welcome to this 6th in the series of blog posts examining the task of creating a Blender Addon to assist with our Second Life Mesh creation workflows.

In the last post, we discovered that all was not quite as it seems in the mesh streaming calculation. Our carefully recreated algorithm repeats all the steps that the published documentation discusses and yet the results did not match. We further learned that this was most likely down to the "estimation" process.

So what is the problem here?

The clue is in the name, "Mesh Streaming Cost" it is intended to "charge" based on the cost of streaming the model; so what does that mean? In real terms it means that they are not looking at the difficulty of rendering an object directly, they are looking at the amount of data that has to be sent across the network and processed by the client. When we export models for use in Second Life we typically use Collada format. Collada is a sprawling storage format that uses a textual XML representation of the data it is very poorly suited to streaming across the internet. This problem is addressed by the use of an internal format better suited to streaming and to the way that a virtual world like Second Life works.

What does the internal format look like?

We can take a look at another of the "hidden in plain sight" wiki pages for some guidance.
The Mesh Asset Format page is a little old, having last been updated in 2013 but it should not have fundamentally changed since then. Additions to SL such as normal and specular maps are not implemented as part of the mesh asset and thus have no effect. It may need a revision in parts once Bento is released.

The page (as with many of the wiki pages nowadays) has broken image links. There is a very useful diagram by Drongle McMahon that tells us a lot about the Mesh Asset Format in visual terms.


In my analysis of the mesh streaming format, it became clear that while Drongle's visualisation is extremely useful it lacks implementation specific details. In order to address this, I looked at both the client source code but also the generated SLM data file for a sample mesh and ended up writing a decoder based upon some of the older tools in the existing viewer source code.
{ 'instance': 
   [ # An array of mesh units
    { 'label': 'Child_0', # The name of the object
                  'material': 
       [  # An array of material definitions
        { 'binding': 'equatorialringside-material',
                     'diffuse': { 'color': [ 0.6399999856948853,
                                             0.6399999856948853,
                                             0.6399999856948853,
                                             1.0],
                                  'filename': '',
                                  'label': ''},
                     'fullbright': False
        }
       ]
       'mesh_id': 0, # A mesh ID, this is effectively the link_id of the resulting linkset
       'transform': [ 10.5, 0.0, 0.0, 0.0,
                      0.0, 10.455207824707031, 0.0, 0.0,
                      0.0, 0.0, 5.228701114654541, 0.0,
                      0.0, 0.0, 2.3643505573272705, 1.0]
    }
   ],
  'mesh': 
   [ # An array of mesh definitions (one per mesh_id)
    { # A definition block
     'high_lod': {'offset': 6071, 'size': 21301},
     'low_lod': {'offset': 2106, 'size': 1833},
     'lowest_lod': {'offset': 273, 'size': 1833},
     'material_list': 
         [ # array of materials used 
          'equatorialringside-material',
          'equatorialringsurface-material',
          'glassinner-material',
          'glassouter-material',
          'strutsinnersides-material',
          'strutsinnersurface-material',
          'strutsoutersides-material',
          'strutsoutersurface-material'
         ],
     'medium_lod': {'offset': 3939, 'size': 2132},
     'physics_convex': {'offset': 0, 'size': 273}
     <compressed data=""> 
     # LENGTH=SUM of all the size parameters in the LOD and Physics blocks
    }
   ],
  'name': 'Observatory Dome', # name of the given link set
  'version': 3  # translates to V0.003
}

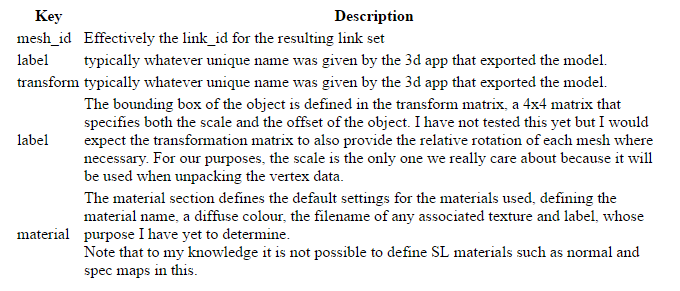
All of this is an LLSD, a Linden Lab structure used throughout the SL protocol,  effectively an associative array or map of data items that is typically serialised as XML or binary. The header portion contains version information, and an asset name, it can also have the creators UUID and the upload date (if it came from the server) .

We also see two other top level markers, 'instance' and 'mesh', this is the stuff we really care about.

Instance

'Instance' is an array of mesh units that form part of the link set. Often when people work with mesh they use a single mesh unit but you can upload multipart constructs that appear inworld as a link set.
Each instance structure contains a set of further definitions.


Mesh

The final entry in the header is the mesh array. Like the instance array before it the mesh array has one entry for each mesh unit and as far as I am able to tell it must be in Mesh_id order.
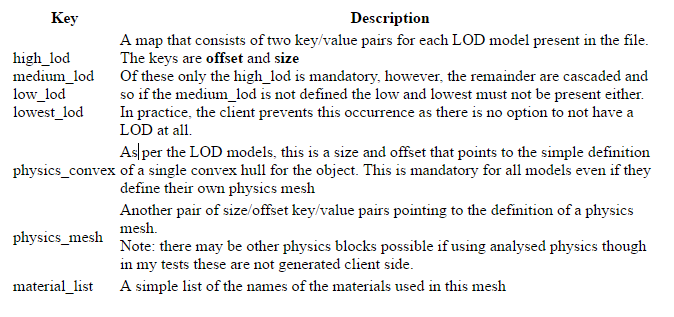
The mesh structure in the array is another LLSD with the following fields:-


At the end of each Mesh is the compressed data that is represented by the bulk of Drongle's diagram and it is for this that we have been waiting for this is why our naive triangle counting solution is giving us the wrong answer.

Compressed mesh data

At the end of each Mesh block is an area of compressed data. Space for this is allocated by the SLM "mesh" entry whose length includes the compressed data even though it is not strictly part of the LLSD.

Once again we need to look at both Drongle's excellent roadmap and the viewer source code to work out precisely what is going on.

As you will recall the Mesh section defined a series of size and offset values, one pair per stored model. In my examples, the physics_convex is always the first model and thus has offset 0.

physics_convex

{ 'BoundingVerts': 'ÿÿÿ\x7f\x00\x00\x81Ú\x81Úa\x18þ\x7fæyþÿÿ\x7f\x00\x00\x
8}%\x81Úa\x18\x00\x00ÿ\x7fa\x18}%}%a\x18ÿ\x7fÿÿa\x181Ö\x16\x86\x97¸ÃŒ)\x17\
                   '¯nÈ\x97¸\x00\x00ÿ\x7f\x00\x00\x9eO\x9aÇ\x94¸Ã„µ\x92í2\x
                   ':Jl\x12.\x0c'
                   '«·a\x133\x0c'
                   'SH\x9dì.\x0c'
                   'T\x85'
                   '\t}þÿªzò\x82þÿF\x85'
                   '\r'
                   '\x83þÿ¸zô|þÿ',
  'Max': [0.5, 0.5, 0.5],
  'Min': [-0.5, -0.5, -0.5]}

Here we see that the compressed data is really just another LLSD map. In this case, we have three keys, Max, Min and BoundingVerts.

Max and Min are important, we will see them time and again and in most cases, they will always be 0.5 an -0.5 respectively. These define the domain of the normalised coordinate space of the mesh. I'll explain what that means in a moment.

BoundingVerts is binary data. We will need to find another way to show this and then to start to unpick it.

['physics_convex']['BoundingVerts'] as hex
dumping 18 bytes:
00000000: FF FF 00 00 00 00 00 00  00 00 FF FF 00 00 FF FF  ................
00000010: 00 00                                             ..

This is the definition of the convex hull vertices, but it has been encoded. Each vertex is made of three coordinates. The coordinates have been scaled to a 1x1 cube and encoded as an unsigned short integer. Weirdly the code to do this is littered throughout the viewer source, where a simple inline function would be far more maintainable. But we're not here to clean the viewer code.
In llmodel.cpp we find the following example

 //convert to 16-bit normalized across domain
 U16 val = (U16) (((src[k]-min.mV[k])/range.mV[k])*65535);

In python, we can recreate this as follows.

def ushort_to_float_domain(input_ushort, float_lower, float_upper):
    range = float_upper - float_lower
    value = input_ushort / float(65535) # give us a floating point fraction 
    value *= range # target range * the fraction gives us the magnitude of the new value in the domain
    value += float_lower # then we add the lower range to offset it from 0 base
    return float(value)

There is an implication to this of course. It means that regardless of how you model things your vertices will be constrained to a 64k grid in each dimension. In practice, you are unlikely to have any issues because of it. And so applying this knowledge we can now examine the vertex data.
expanding using LittleEndian
0: (65535,0,0)->(0.500000,-0.500000,-0.500000)
1: (0,0,65535)->(-0.500000,-0.500000,0.500000)
2: (0,65535,0)->(-0.500000,0.500000,-0.500000)
Max coord: 65535 Min coord: 0

It is my belief that these are little-endian encoded. The code seems to support this but we may find that we have to switch that later.

We can apply this knowledge to all sets of vertices.

Onwards into the Mesh

Looking into the compressed data we find that the LOD models now follow. They follow in the order that you'd expect, lowest to high.

Each LOD model represents the actual vertex data of the mesh. Mesh data is stored as a mesh per material, thus we find the compressed data section per LOD is comprised of an array /list of structures or what Drongle refers to as a submesh in his illustration, one element of the array for each material face. Each material face is the comprised of a structure of the following:
Field
Description
Normal
A list of vector normal that corresponds to the vertices
Position
The vector cords of the vertices
PositionDomain
The min and max values for the expanded coord data (as per the preceding physics section)
TexCoord0
The UVW mapping data. At present, I have not investigated the encoding of this, but it would appear to be the case that these are encoded identically to the Vertex data but with only the X and Y components.
TexCoord0Domain
The min/max domain values associated with the UVW data
TriangleList
The mesh, a list of indices into the other data fields (the Position, TexCoord and Normal) that form the triangles of the mesh itself. Each triangle in the lost is represented by three indices, which refer uniquely to an entry in the other tables.Individual indices may of cours be shared by more than one triangle.

I think this is more than enough for one post. We've covered a lot of ground.
I am now able to successfully decode an SLM asset in Python and so next we can see how this helps us calculate the LI.

love Beq
x

Thursday, 7 July 2016

The truth about mesh streaming

The truth about mesh streaming

Ever wondered why a mesh with the same number of triangles could give different LI? Or how the impact of each LOD model is assessed? Stick with me today and hopefully, I'll show you.

Today's post is the fifth in the series of meanderings through Blender Addons. Yesterday, we left things in an OK state. My AddOn is reflecting the correct triangle counts for the models (and correctly associating the models with the LOD they represent).

Today we will look at the Mesh Streaming Cost algorithm and have a go at converting that to python.
This is an unashamedly technical blog. I will try to explain some aspects as I go through but the nature of the topic demands some technical detail, quite a lot of it.

I am going to work from the latest Firestorm Viewer source, and a couple of somewhat outdated wiki resources. The wiki resources themselves should be good enough, but the problem with them is that you can never be sure if things have been tweaked since. Ultimately though we have a real world comparison, our estimates should match (or be close to) the Viewer upload, we will test this at the very end.

A good place to start is the Mesh Streaming Cost wiki page as with many wiki documents it is out of date and not entirely correct. However, we can use it as a starting place. The concept section explains the thought behind this. The equation part is where we will start.
  1. Compute the distance at which each LOD is displayed
  2. Compute the area in which each LOD is relevant
  3. Adjust for missiing LODs
  4. Scale relative weights of each LOD based on what percentage of the region each LOD covers.
  5. Compute cost based on relevant range and bytes in LOD
It goes on to tell us what the LOD transition distances are, details we covered in the post yesterday.

Using these we can write another helper function
def getLODRadii(object):
    max_distance = 512.0
    radius = get_radius_of_object(object)
    dlowest = min(radius / 0.03, max_distance)
    dlow = min(radius / 0.06, max_distance)
    dmid = min(radius / 0.24, max_distance)
    return (radius, dmid, dlow, dlowest)

This function takes an object and using our previously written radius function and applying the knowledge above, returns a list of values. The radius itself, the High to Mid transition distance, The Mid to low transition and finally the Low to Lowest.

We use a constant max distance of 512 as it matches that used in the code example and the current live code. Quite why it should be 512 (2 regions) is unclear to me.

So now we should be able to add a new column to our display and show the LOD change radii

Step 2 is to compute the area for each LOD. Now that we have the Radius that is a simple task.

def area_of_circle(r):
    return math.pi * r * r

The function above returns the area for a given radius.

The next step is "Adjusting for missing LODs", we'll take this into account when we display things. But in terms of the algorithm, if a given LOD is missing then the next highest available LOD is used.

We can now progress to the "Computing Cost" section. This section gives use the following formula.

    Streaming Cost =
        (   (lowest_area / total_area) * bytes_in_lowest
          + (low_area    / total_area) * bytes_in_low
          + (mid_area    / total_area) * bytes_in_mid
          + (high_area   / total_area) * bytes_in_high   ) * cost_scalar
The first part is a ratio, a weighting applied to the LOD based upon the visibility radii.
The second part is more confusing on its own, "bytes_in_LOD" where did that come from?

The answer lies in the note just below the pseudo code.
In the details of the implementation, the cost_scalar is based on a target triangle budget, and efforts are made to convert bytes_in_foo to an estimated triangle count.
So what does that mean exactly? The answer lies in the C++ code below it and, in particular:
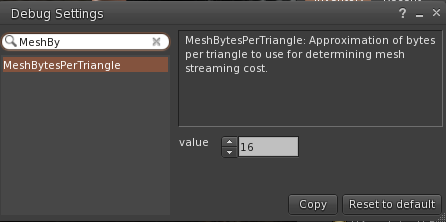
F32 bytes_per_triangle = (F32) gSavedSettings.getU32("MeshBytesPerTriangle");
This is a setting stored in the viewer that approximates how many bytes are in a triangle for the purpose of converting "bytes" to triangles. Looking at the current live viewers, we find that the setting has a value of 16.

This value is then used to convert a bytes_LOD value to a triangles_LOD value.
    F32 triangles_high   = llmax((F32) bytes_high-METADATA_DISCOUNT, MINIMUM_SIZE
                            /bytes_per_triangle;
This deducts a METADATA_DISCOUNT constant to remove the "overhead" in each mesh LOD to leave only the real triangle data. The remaining bytes are divided by our bytes_per_triangle to get the number of triangles. This raises the question of whether 16 is the right "estimate" Indeed, why is it an estimate at all? In Blender we won't be estimating, we know how many triangles we have. However, it will turn out that the page is missing one vital piece of information that explains all of this...However, we will come back to this once we have worked out the rest.

Looking in more detail at the implementation we find that lowest area and the related "areas" are not quite what they seem.
In the C++ implementation, we observe that high_area is indeed the area of the circle defined by the roll off point from High to Medium LOD,
F32 high_area   = llmin(F_PI*dmid*dmid, max_area);
but we discover that mid_area is the area of the medium range only, excluding the high_area. The area of the Ring in which the Medium LOD is visible.The same applies to the others.

Putting this all together in python we get the following:-

def getWeights(object):
    (radius, LODSwitchMed, LODSwitchLow, LODSwitchLowest) = getLODRadii(object)

    MaxArea = bpy.context.scene.sl_lod.MaxArea
    MinArea = bpy.context.scene.sl_lod.MinArea

    highArea = clamp(area_of_circle(LODSwitchMed), MinArea, MaxArea)
    midArea = clamp(area_of_circle(LODSwitchLow), MinArea, MaxArea)
    lowArea = clamp(area_of_circle(LODSwitchLowest), MinArea, MaxArea)
    lowestArea = MaxArea

    lowestArea -= lowArea
    lowArea -= midArea
    midArea -= highArea

    highArea = clamp(highArea, MinArea, MaxArea)
    midArea = clamp(midArea, MinArea, MaxArea)
    lowArea = clamp(lowArea, MinArea, MaxArea)
    lowestArea = clamp(lowestArea, MinArea, MaxArea)

    totalArea = highArea + midArea + lowArea + lowestArea

    highAreaRatio = highArea / totalArea
    midAreaRatio = midArea / totalArea
    lowAreaRatio = lowArea / totalArea
    lowestAreaRatio = lowestArea / totalArea
    return (highAreaRatio, midAreaRatio, lowAreaRatio, lowestAreaRatio)

This should give us the weighting of each LOD in the current models at the current scale. So let's add this to our display.

Here we can see that our Medium and Low LODs are carrying a lot of the LI impact and thus if we want to manage the LI we need to pay a lot of attention to these. The more observant will note that the Lowest is effectively 0, and yet we are telling it to use the LOD from the LOW, this makes no sense at first glance, it should be very expensive. The explanation is in the radius column. Lowest does not become active until 261m, which is outside of the 256m maximum  (see maxArea in the code above), this means that the Lowest is clamped to a radius of 256, which matches the radius of the Low and thus results in 0 weight.

With all this in place, we are finally able to have a first run at calculating the streaming cost.
Once again we refer to the C++ implementation for guidance.
    F32 weighted_avg = triangles_high*high_area +
                       triangles_mid*mid_area +
                       triangles_low*low_area +
                       triangles_lowest*lowest_area;
 
    return weighted_avg/gSavedSettings.getU32("MeshTriangleBudget")*15000.f;
 In our python translation this becomes:

        weightedAverage =   hi_tris*highAreaRatio + mid_tris*midAreaRatio + low_tris*lowAreaRatio + lowest_tris*lowestAreaRatio
        streamingCost = weightedAverage/context.scene.sl_lod.MeshTriangleBudget*15000

I am not a fan of the magic numbers used here (MeshTriangleBudget is in fact another viewer setting and has a value of 250000, the 15000 however is a simple hard coded constant so we have little choice but to replicate it.

For our final reveal for tonight then let's see how out LI calculation has performed.


Oh dear...
Well, I guess it had all been too easy so far.
The Firestorm upload has calculated that this object will have a streaming impact of 8LI
Our determination has calculated 13LI. That is a considerable difference, what could possibly have gone wrong?

The answer was hinted at previously; it is to do with the estimate, the bytes_LOD values and what they actually are. The problem lies in the fact that your mesh is not sent back and forth unaltered from the DaE file that you upload. In fact, it is uploaded in an internal format that compresses each LOD model. The bytes_LOD values represent the compressed size of the actual mesh that will be streamed, the estimated bytes_per_triangle of 16 is, it would seem greatly underestimating the compression level.
In my next blog, I will examine the internal format in more detail. We'll explain why the estimated bytes per triangle is wrong, and we will start to work out how we can make this work.

Until then, thank you for reading this blog. Please share or +1 if you have found it useful, or if you think that your friends might.

Love
Beq
x

Saturday, 2 July 2016

Tell your friends - An old bug that people really ought to know about.

I was reminded today that people remain largely unaware of an old bug spotted five years back by Drongle McMahon and which remains unfixed.

I first became fully aware of this during an investigation with Antony Fairport and the ensuing discussions with Rey (Chinrey). Given that it remains a problem and that many people do not realise it, I thought I would write a quick and concise (by my standards) example of what the problem is.

Summary: Due to a bug in the viewer, the bounding box for meshes with only 3 or 4 faces ignores the Z-axis completely.

You may recall that the bounding box is important when considering the transition between LODs. My 2012 blog post "Too much information" explains the role of the bounding box for those unfamiliar.
Given that the radius (r) is defined in terms of all the axes, if Z is dominant and then ignored, the effective radius is much smaller than it ought to be and as a result, the LOD transitions happen a lot sooner.

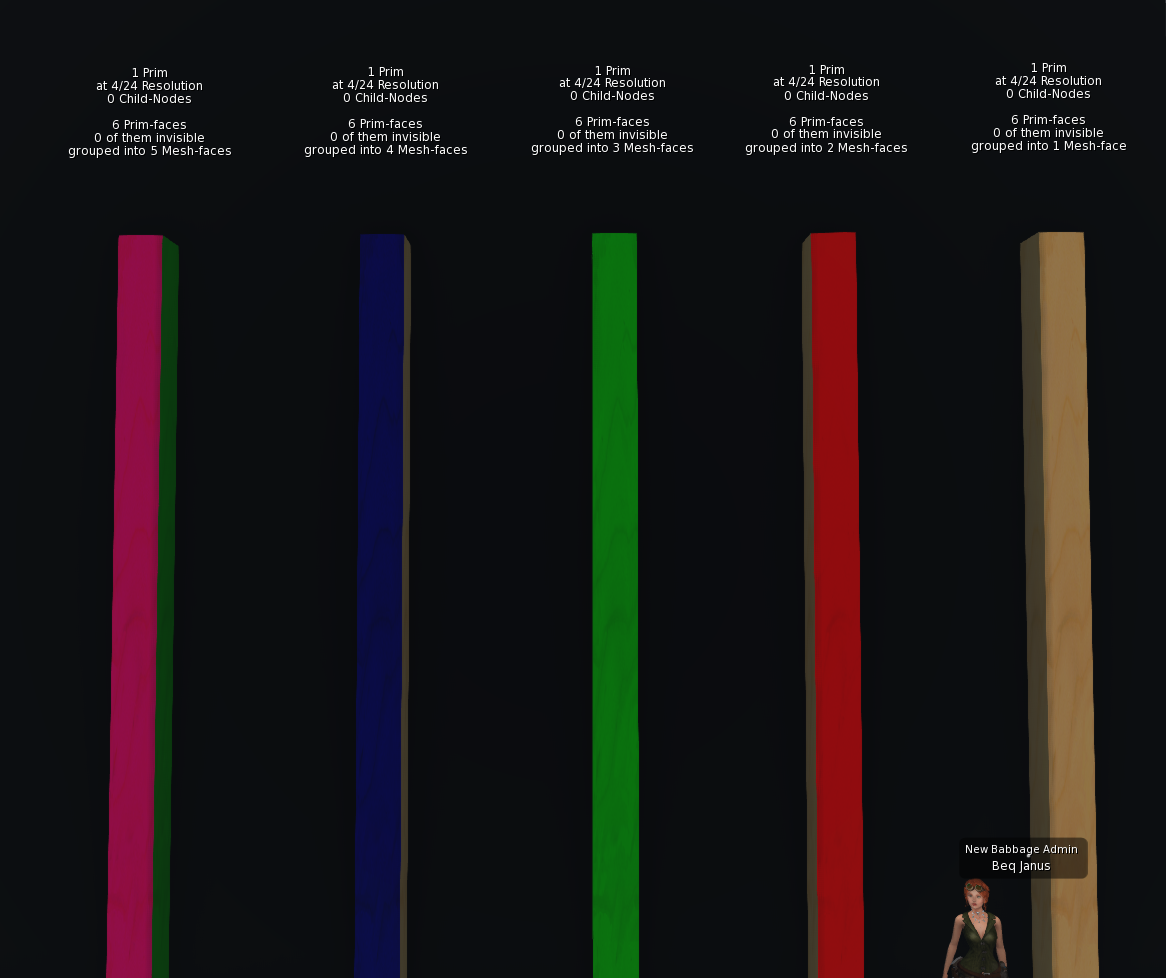
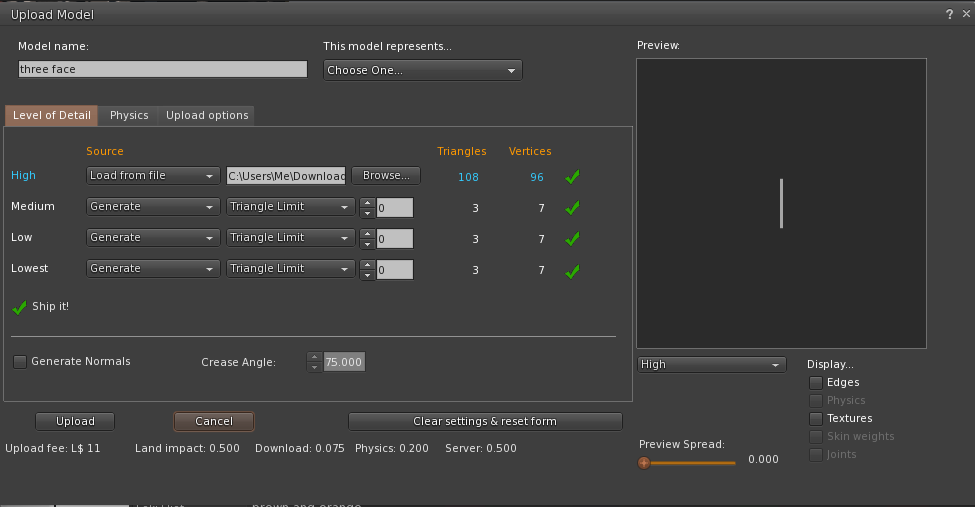
The demonstration is very simple. I created five identical Mesh columns using Mesh Studio (MS). I gave them each a different number of texture faces. Right to left in the image we have the prim models for one face through to five with the MS floating text to confirm this.

They were then each uploaded identically. The model was the HIGH and all other LOD models were minimised so that the object would collapse to minimal triangles as soon as the HIGH LOD went out of range.

Lining these all up alongside their prim equivalents and panning out demonstrates the issue very clearly as the following gif shows.
I hope that this helps make the issue a little more obvious and if you are only now learning, or being reminded of this, then please share as widely as you can so that people are not accidently impacted by it.

Bye for now

Love Beq
x